Behaviour commands: 1 B steps with the robot's joint limits
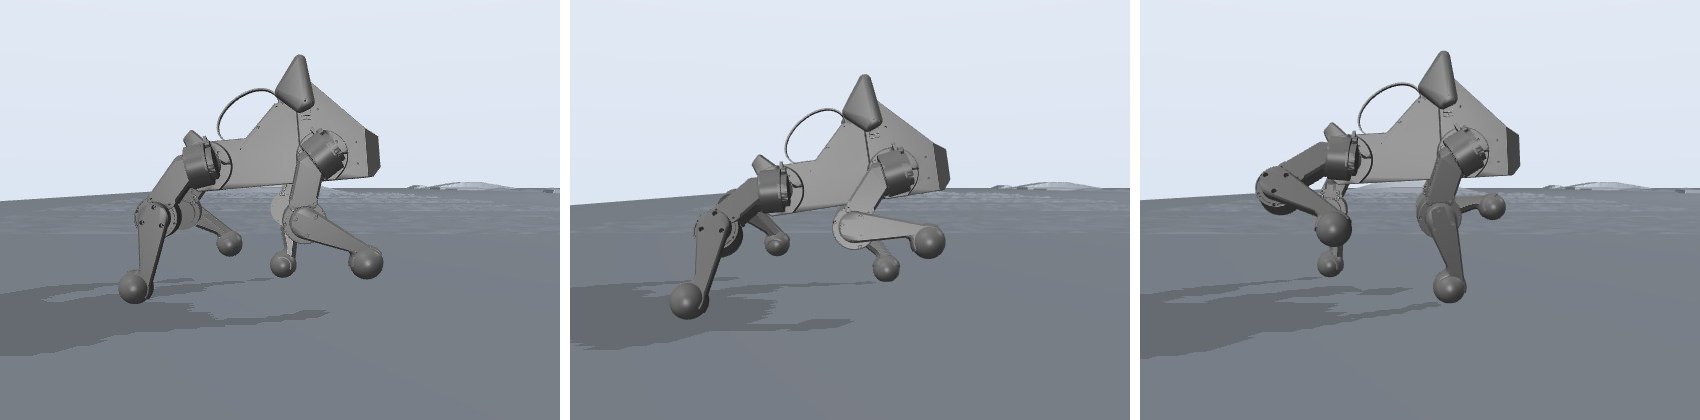
The behaviour policy trained for 1 B steps with a stronger height reward and the robot's joint limits follows every command on flat ground, the 13 cm crouch included. It was evaluated as on the robot, with joint commands clamped 0.1 rad inside each stop and a leg resting on its stop not counted as a fall.
- Flat ground: crouch 14.1 cm at a 13 cm command, swing 7.7 cm at 8 cm, 4 Hz steps at 3.99 Hz, 10° nose-up pitch followed
- Crouch passes on 3 cm stairs / 15° slope / 5 cm curb, ramped edges of the training terrain: 26 / 21 / 25 = 72 of 90; in the same evaluation the 200 M-step run 69 (14.7 cm) and the policy before the height fix 81 (16.0 cm)
- High step on the 5 cm curb 29 of 30, 4 Hz steps on the 15° slope 30 of 30, standing 0 of 30 episodes ended
- Still open: the crouch on the 15° slope (21 of 30) and the pitch command on stairs and slopes