Driving the walking stack in simulation
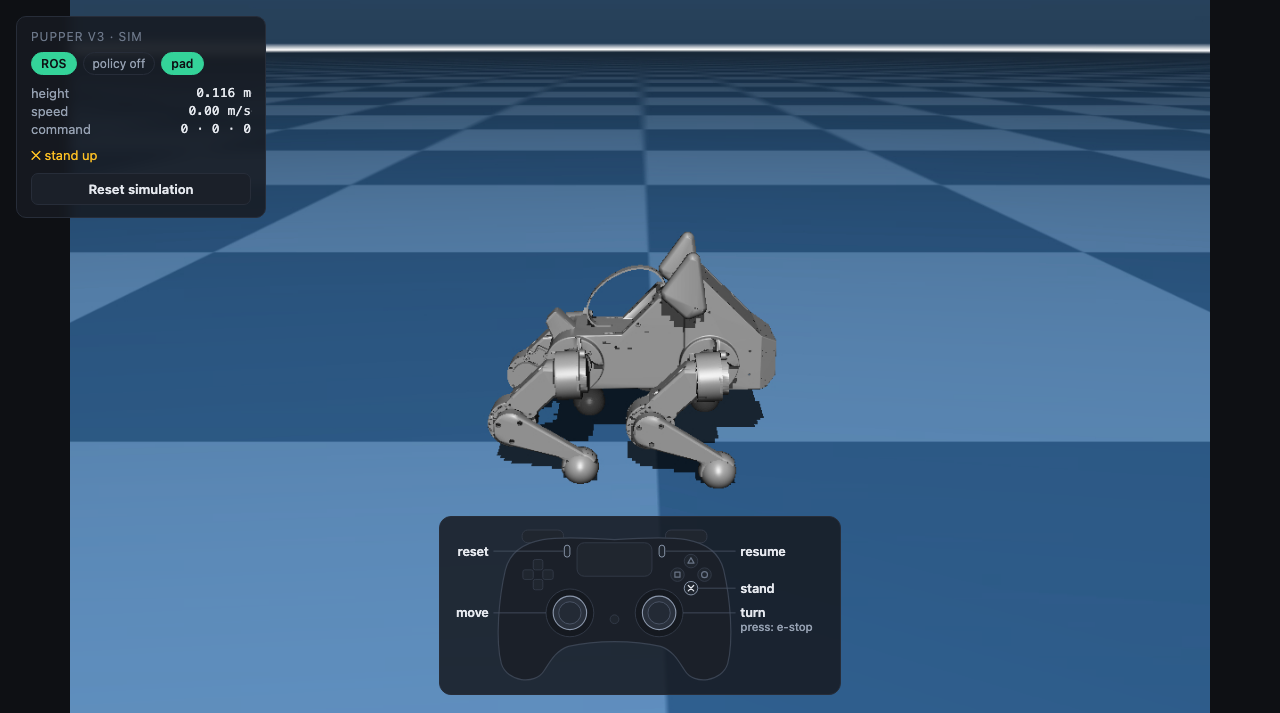
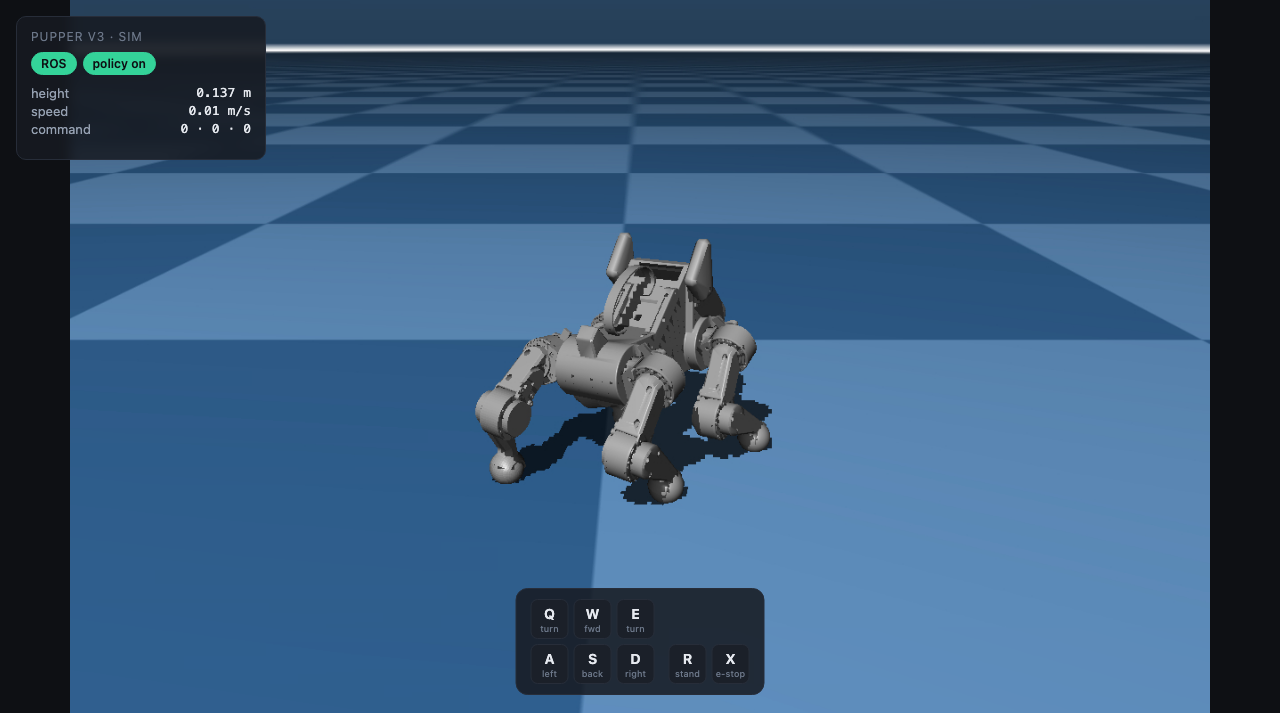
The robot's ROS 2 stack runs with MuJoCo in place of the hardware and is driven from the browser with keys or a DualSense pad.
- Standing height: ours 0.14 m, official 0.18 m
- Pitch-rate RMS at 0.5 m/s, re-measured on Oct 9 with lockstep physics: ours 1.14–1.18, official 1.40 rad/s